www.auto-innovations.net
16
'26
Written on Modified on
Automated Driving Systems Architecture for Real-Time Sensor Processing
Volvo Cars integrates NVIDIA Hyperion architecture and Halos software to resolve centralized sensor compute bottlenecks in production vehicles.
www.nvidia.com
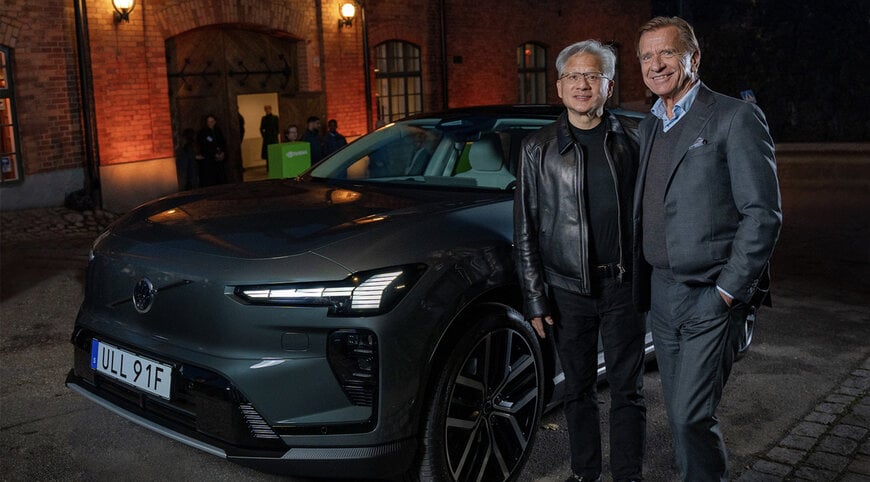
Volvo Cars and NVIDIA have expanded their joint development program to implement centralized high-performance computing platforms for scalable automated driving applications. The initiative deploys unified hardware and software architectures into next-generation passenger vehicles to support autonomous navigation across urban environments, highways, and parking facilities.
Centralized Compute and Software Architecture
The technical cooperation combines NVIDIA accelerated computing hardware with Volvo Cars vehicle safety integration and control systems. NVIDIA supplies the Hyperion sensor and compute architecture, which functions as the hardware baseline for high-bandwidth automotive data acquisition and real-time processing. This platform interfaces directly with Halos operating software and the Alpamayo Stack driving software, providing a consolidated environment for sensor fusion, perception pipelines, and vehicle path planning.
Volvo Cars oversees system validation, mechanical packaging, and the integration of functional safety logic across the vehicle chassis. By transitioning from distributed electronic control units to a centralized computing topology, the architecture processes high-throughput streams from cameras, radar, and complementary sensing modalities on a single platform. This compute consolidation reduces system latency and eliminates communication bottlenecks inherent in legacy automotive electrical networks.
Sensor Ingestion and Operational Safety Logic
The integrated system executes edge-level artificial intelligence workloads to interpret complex driving domains. During operation, the NVIDIA compute platform ingests raw telemetry and environmental sensor data to construct dynamic spatial models around the vehicle. The Halos software layer arbitrates system resources to maintain deterministic performance, ensuring safety-critical tasks execute within defined latency boundaries.
Volvo Cars applies deterministic safety algorithms and operational control limits derived from long-term real-world collision data. This approach establishes a dual-layer architecture: accelerated deep learning networks handle object classification and trajectory prediction, while deterministic control software enforces fail-safe parameters, fallback maneuvers, and collision mitigation strategies.
Vehicle Deployment and Phased Automation
The platform is engineered for deployment within software-defined electrical architectures on upcoming production vehicle lines. Initial commercial implementations focus on driver-assistance functions, providing verified compute headroom for over-the-air software updates. As regulatory standards and operational design domains permit, the hardware and software configuration supports transition paths toward eyes-off and mind-off automated driving modes.
Accelerated computing platforms provide the computational density required for real-time sensor processing and redundant execution, establishing an industrial foundation for scalable vehicle automation.
Edited by Natania Lyngdoh, Induportals editor, with AI assistance.
www.nvidia.com
